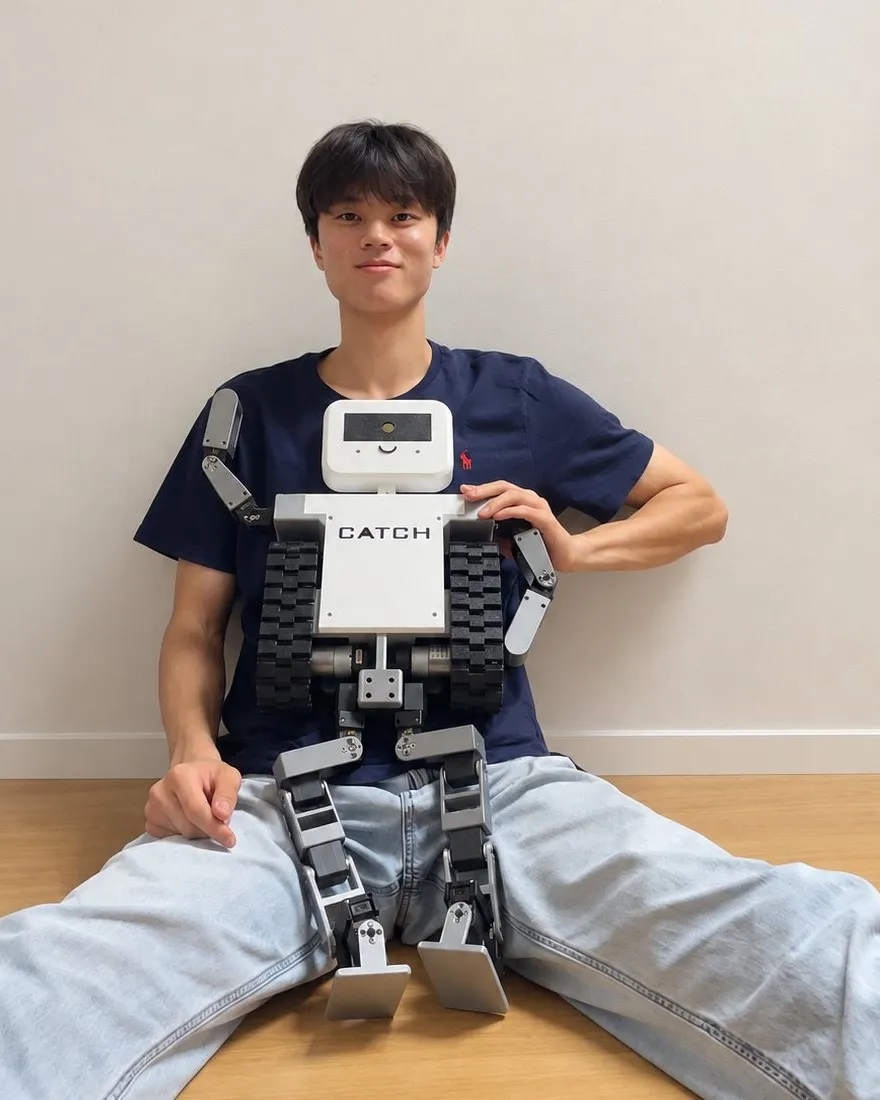
Yobel Sungkook Lee
Robotics ResearcherB.S. Mechanical Engineering, Sungkyunkwan University
I want to build many kinds of robots, each with its own character and purpose, that people want to have around and can rely on. A robot's character comes from both its body and how it moves, yet the two are usually designed separately. I want to design them together, using morphology-conditioned policies that can control many different bodies, so a new design can be tested in simulation before it is built.
So far I've designed and built a worm-inspired robot that crawls across colon tissue and a pipe inspection robot, trained reinforcement-learning controllers for legged robots, and I'm now building CATCH, a small humanoid designed to drive on tracks and stand on legs.
Email: yobel.s.lee [at] gmail [dot] com
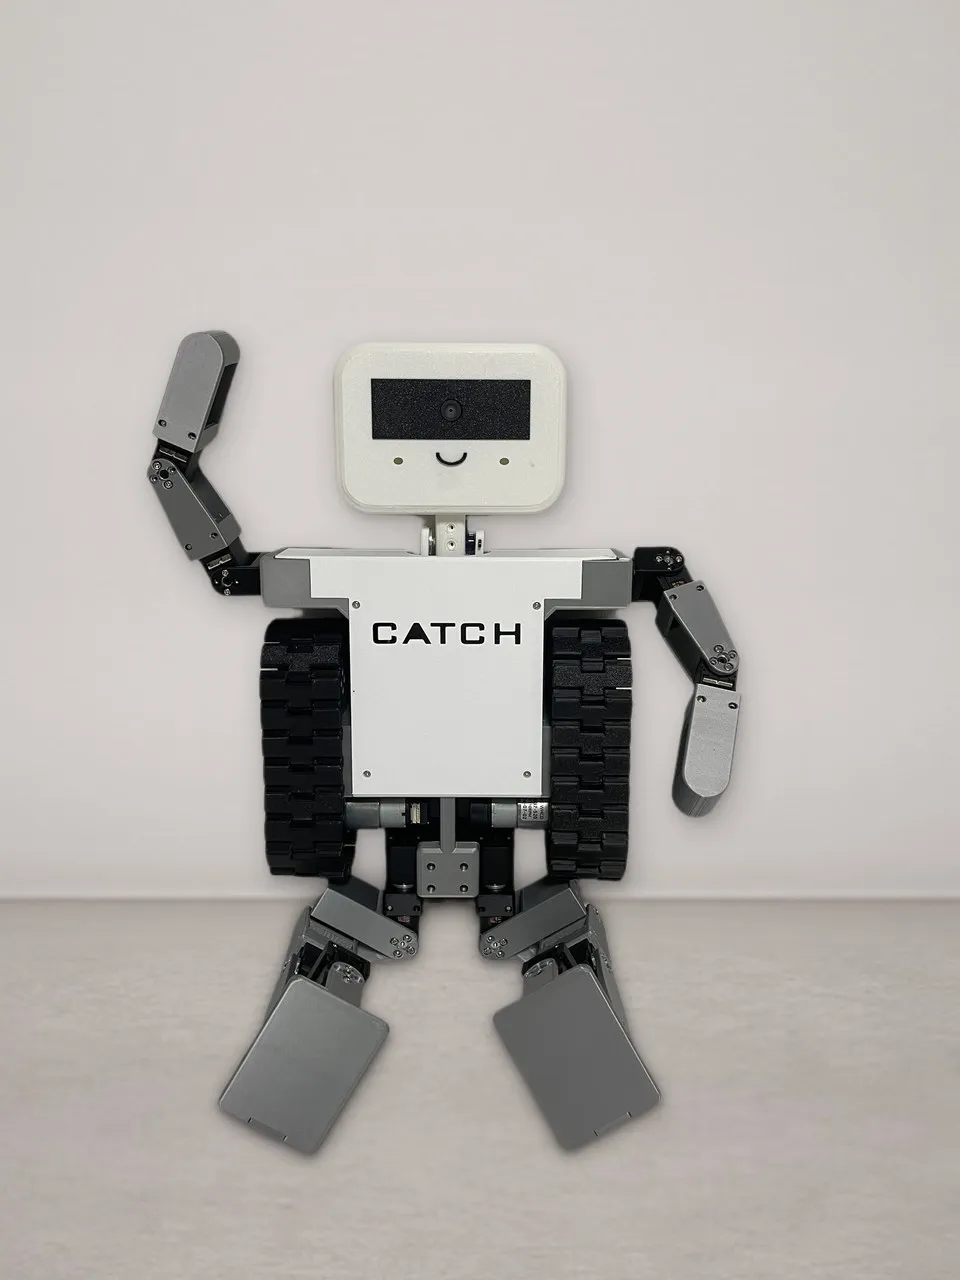
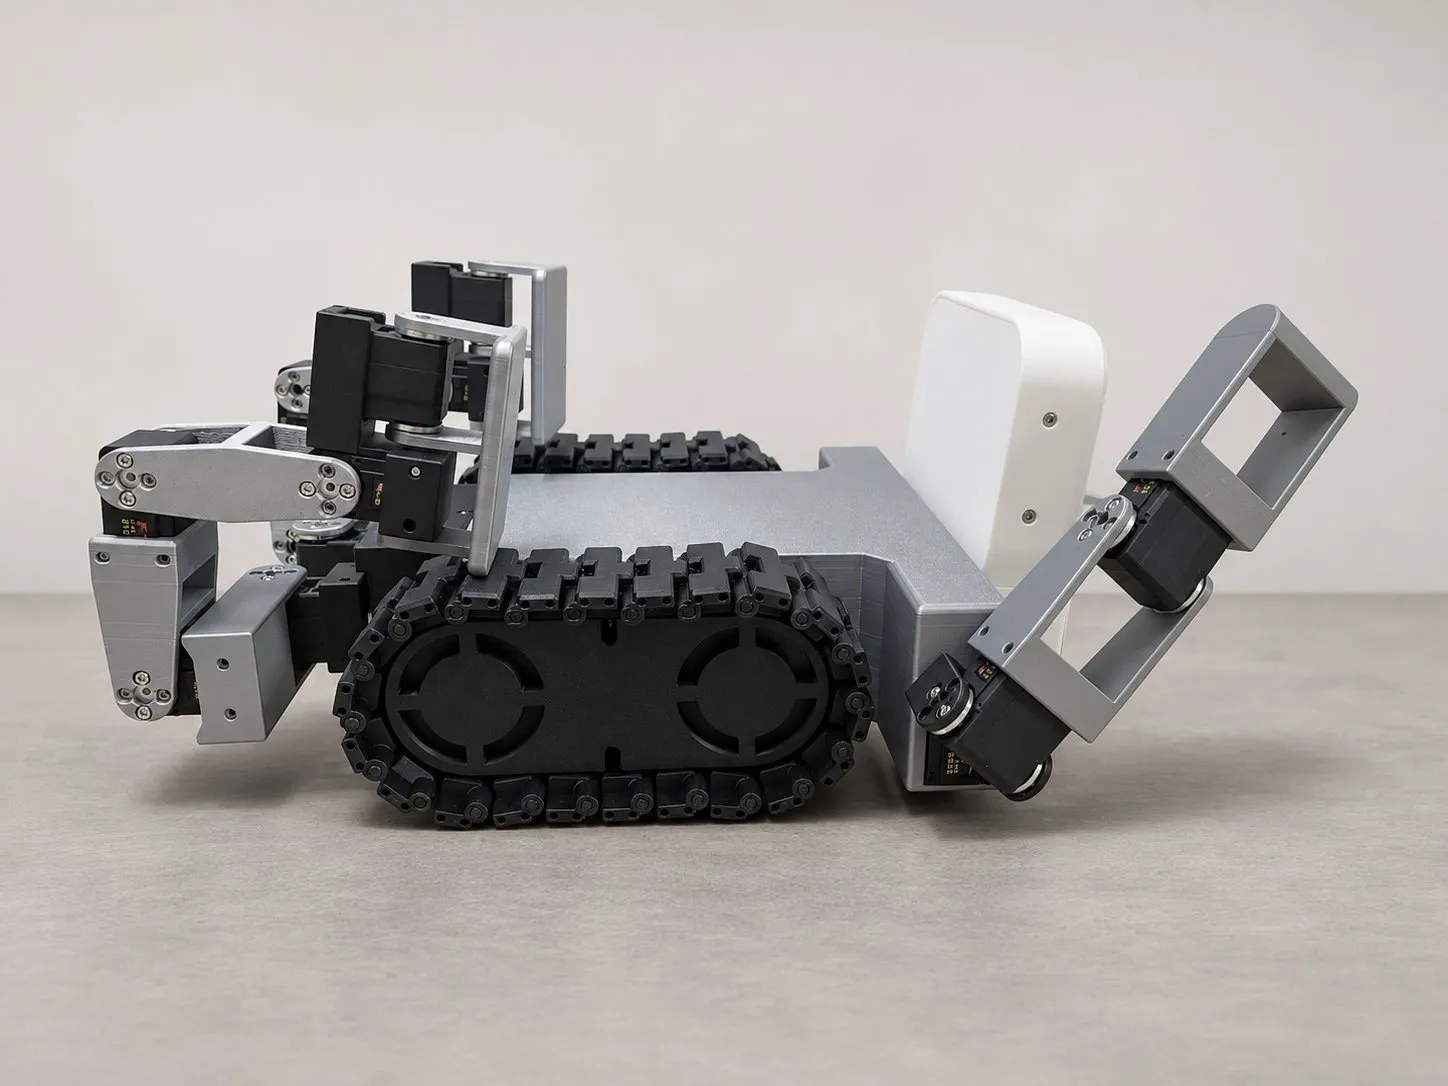
CATCH, my current project, sitting upright and folded into tracked mode. Watch the progress video
Projects
- CATCH in CAD: the full assembly coming apart, electronics placed in the torso, and the wiring map of all 191 connections.
CATCH
One small body designed to change shape with the task: folded low on its tracks to travel, or upright to reach out and interact with its arms and legs. I designed it in CAD, 3D printed it, and assembled it; the wiring is fully planned but not yet built.
Built · Not yet powered on
- Time-lapse of the WORM robot crawling forward step by step.
WORM
A worm-inspired colonoscopy robot that crawls through the colon by switching its adhesive pads between gripping and slipping. I led its hardware design, prototyping, and control, using an adhesive from a collaborating materials lab.
Tested ex vivo · Manuscript under review
- Gyecko crawling through a clear pipe, seen from above.
Gyecko
A 241 g gecko-inspired robot that inspects pipes from the inside, turning at a center joint to follow bends and stepping on stamp-type feet with sticky pads. Built by a team of six that I led, it crawled autonomously through dry, wet, and 30° inclined pipes, detecting obstacles along the way.
Built · Tested
- A simulated Unitree Go2 climbing a series of high steps.
Go2 Extreme Parkour
A PPO-based perceptive locomotion framework for the Unitree Go2, and a study of how terrain information should reach the Actor and the Critic. In simulation, the best configuration crosses 80 cm gaps and climbs 45 cm parkour steps.
Simulation
Publications
A strain-triggered pseudo-gel transition for instantaneous and reversible adhesion switching
Design and Implementation of AI Machine Vision Inspection System with Multi-Optical Images for OLED Film Manufacturing
Experience
- 2026–CATCH · Independent project
- 2025–FineVT · Robotics & ML Researcher, alternative military service
- 2025–26LAIR, Sungkyunkwan University · Research Intern
- 2024–25AMRL, Sungkyunkwan University · Undergraduate Researcher
- 2024Dynamic Robotics Systems Lab, Seoul National University · Undergraduate Researcher
- 2023AIDIN · Intern, Sensor Development Team
- 2021–25Sungkyunkwan University · B.S. Mechanical Engineering, summa cum laude, ranked 1st of 186