Skip to content
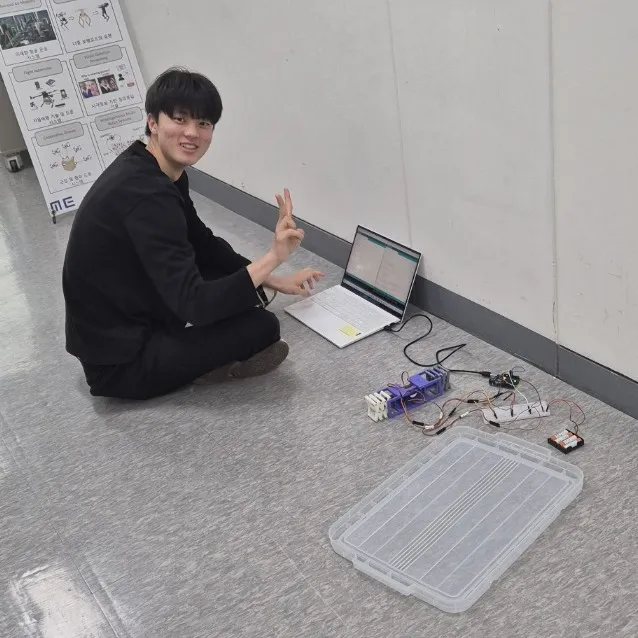
Yobel sitting on the floor of a lab hallway, smiling and making a V sign, next to a laptop, the WORM robot with its control boards, and a clear test tray.
With WORM at SKKU AMRL.

About

I love imagining new kinds of robots and figuring out how to build them. What draws me to robotics is the possibility of creating robots that are not only useful but also endearing, with distinctive bodies and expressive movements that give them character. My background is in mechanical engineering, and my curiosity has gradually taken me from hands-on robot design and fabrication to learning-based control.

I studied mechanical engineering at Sungkyunkwan University, graduating summa cum laude and first of 186 in my department. At the Advanced Mobility and Robotics Lab, I led the robot design of WORM, a worm-inspired colonoscopy robot developed in close collaboration with a materials lab. I later led a team of six to build Gyecko, a compact pipe-inspection robot designed to navigate turns in confined spaces. On the learning side, I adapted a reinforcement-learning controller for the Bolt biped and developed a perceptive locomotion framework for the Unitree Go2 at SKKU's Lab of Artificial Intelligence & Robotics to investigate how terrain observations and their representations affect Actor–Critic locomotion learning (Go2 Extreme Parkour).

Since 2025, I've been a Robotics & ML Researcher at FineVT, where I'm completing Korea's alternative military service. There, I collaborate with a senior colleague on an AI-agent-driven robotic system. While he develops the AI agent, I focus on the robot-control and execution layer that connects the agent's decisions to physical robot-arm motion and camera operations. I also work on a multi-view 3D reconstruction pipeline that turns captured images into 3D models.

Outside of work, I'm building CATCH, a custom transformable humanoid designed to combine legged locomotion with torso-mounted tracks. CATCH is also the first testbed for a design-to-learning pipeline I'm developing to connect CAD, simulation, learning-based control, and eventually hardware deployment. I hope it will eventually feel like a playful little friend, able to express itself through movement and gestures.

These experiences have made me think about how closely a robot's body and behavior are connected. In the long run, I want to create many kinds of robots, each with its own character and purpose, that people can both rely on and enjoy having around. To explore new bodies and behaviors without starting from scratch each time, I want to studybody–policy co-design and morphology-conditioned predictive models that can help evaluate how a new robot body might behave before it is built.

I hold both U.S. and Korean citizenship. If you're building robots with character, or researching how a robot's body and behavior shape each other, I'd be glad to hear from you.

Research interests

  • Robot embodiment designCATCHWORMGyecko
  • Expressive robotics & animatronicsCATCH
  • Body–policy co-design
  • Morphology-conditioned predictive models
  • Reinforcement-learning-based controlGo2 Extreme Parkour
  • Sim-to-real transfer

Education

  1. 2021.02 – 2025.02

    B.S. in Mechanical Engineering, Sungkyunkwan University

    GPA 4.4/4.5, summa cum laude, ranked 1st of 186.

Experience

  1. 2026.07 – present

    CATCH, Independent project

    Designed, 3D printed, and assembled the mechanical prototype of a custom transformable humanoid with legs and torso-mounted tracks; all 191 electrical connections are planned in CAD but not yet wired. It is the first testbed for a design-to-learning pipeline that connects CAD, simulation, and learning-based control.Project →

  2. 2025.02 – present

    Robotics & ML Researcher, FineVT (alternative military service)

    Developing the robot-control and execution layer of an AI-agent-driven robotic system (Jetson runtime, MCP/FastAPI interfaces), which turns the agent's decisions into robot-arm motion and camera operations, and a multi-view 3D reconstruction pipeline. Also built a display-inspection segmentation model (best test IoU 0.974) and hyperspectral internal-defect detection for four fruit types (Extra Trees, about 99.8% F1).

  3. 2025.07 – 2026.01

    Robotics Research Intern, Lab of Artificial Intelligence & Robotics (LAIR), Sungkyunkwan University

    Built a PPO-based perceptive locomotion framework for the Unitree Go2 in NVIDIA Isaac Lab and compared five Actor⁠–⁠Critic observation and encoding configurations. Separate 32‑D terrain encoders for both networks reached the highest final training reward and cleared 80 cm gaps and 45 cm parkour steps in representative simulation runs.Project →

  4. 2024.01 – 2025.07

    Undergraduate Researcher, Advanced Mobility and Robotics Lab (AMRL), Sungkyunkwan University

    Led the robot design, prototyping, and control of WORM, which crawled to the end of the tested ex vivo bovine colon segment in 16 locomotion cycles (manuscript under review). Led the development of Gyecko, a pipe inspection robot with a custom rack-and-pinion actuator that reduced the actuator's width by 7.8 mm; it navigated and detected obstacles in dry, wet, and 30° inclined pipes.WORM →Gyecko →

  5. 2024.07 – 2024.08

    Undergraduate Researcher, Dynamic Robotics Systems Lab, Seoul National University

    Designed and implemented a reinforcement-learning controller in C++ with ROS, and adapted it for the 6‑DoF Bolt biped in MuJoCo, sim-to-sim from Isaac Gym.

  6. 2023.09 – 2023.12

    Research Assistant, Smart Factory Capstone Design Course, Sungkyunkwan University

    Implemented and evaluated a 5-way 5-shot Prototypical Network on CUB-200 and surveyed few-shot methods for visual defect classification; contributed the literature review and related work for an IEEE BCD 2023 paper.

  7. 2023.06 – 2023.09

    Intern, Sensor Development Team, AIDIN

    Designed the schematics and PCB layout, in Altium CircuitMaker, for a custom magnetic absolute encoder built on an iC-Haus chip for higher resolution.

  8. 2022.12 – 2023.02

    Undergraduate Researcher, Robotics and Intelligent System Engineering Lab, Sungkyunkwan University

    Designed and implemented PID control with gravity compensation on Arduino for the position and speed of a 1‑DoF rigid body, and modeled a gearbox in Simulink.

Teaching & outreach

  1. 2025.10 – 2025.11

    Special Lecturer, Autonomous Driving & Edge AI, MAICON, Ministry of National Defense and Republic of Korea Air Force

    Co-developed a hands-on autonomous-driving course and taught it to Republic of Korea Air Force personnel at their unit, using Omo robots and Jetson Nano: dataset labeling, YOLOv8 perception, and PID and sliding-window navigation.

  2. 2024.03 – 2025.02

    Makerspace Manager, Center for Innovative Engineering Education, Sungkyunkwan University

    Ran the 3D printers, laser cutters, and other prototyping tools, and helped students use them.

Honors

  1. 2025.01

    Highest Honor, Co-Deep Learning Project, Sungkyunkwan University

    As team lead of Gyecko, for innovation in system design, hardware integration, and field-navigation performance.Gyecko →

  2. 2023.03 – 2025.02

    National Science and Technology Scholarship, Korean Government

    Awarded for top academic performance; full-tuition scholarship support through graduation ($3,500 per semester).

Tools

Programming and ML
Python, C/C++, MATLAB, PyTorch
Robotics and simulation
ROS/ROS 2, NVIDIA Isaac Lab, Isaac Sim, MuJoCo, Gazebo
Design and fabrication
Autodesk Fusion, Autodesk Inventor, Altium CircuitMaker, 3D printing, laser cutting

Contact